Physical AI in the Real World: Four Requirements for Reliable Robot Manipulation
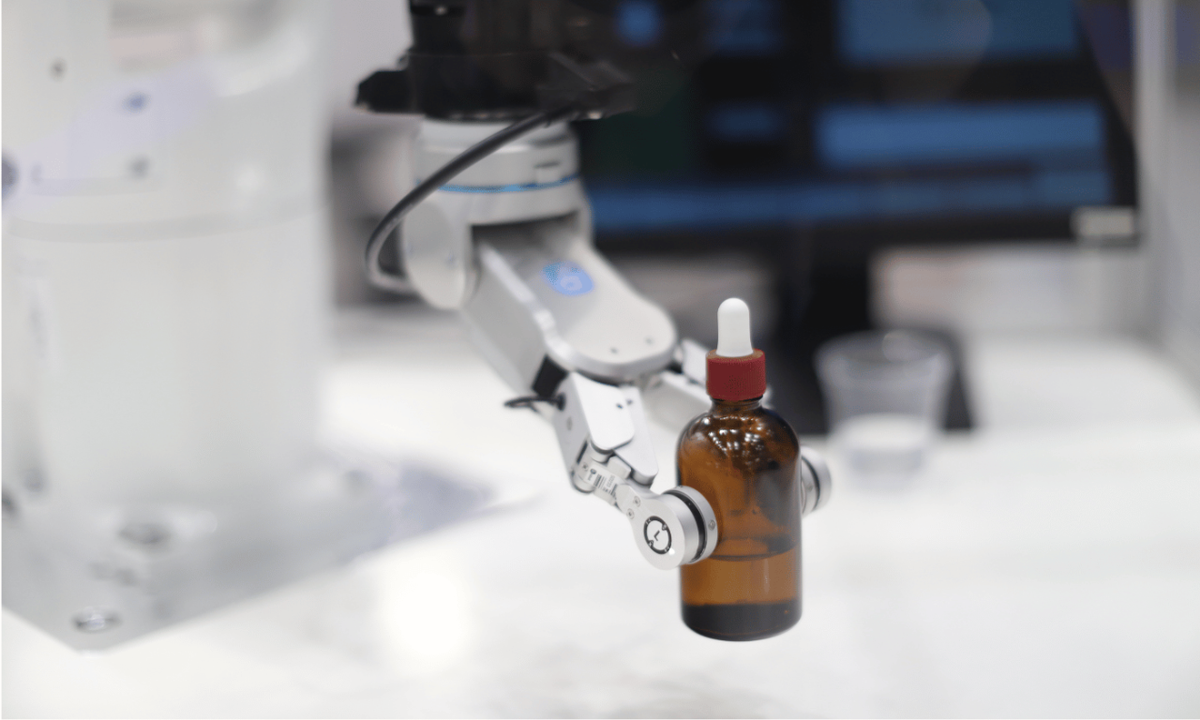
Physical AI promises robots that can perceive, act and adapt in the physical world with far less task-specific engineering than traditional automation.
It’s a compelling proposition: robots powered by AI models trained on vast amounts of data, capable of improving over time and operating effectively in far less structured environments. But how do we get there?
As AI systems move from the digital to the physical world, new requirements emerge. Intelligent models and policies remain essential, but they are only a part of the equation. Robots ultimately interact with the physical world through grippers, sensors and tools that make direct contact with objects.
For physical AI to deliver on its promise, it needs a reliable physical interaction layer: End-of-arm tooling (EOAT) that combines adaptability, sensing and feedback so robots can respond effectively to uncertainty and variation.
In selecting the right EOAT for physical AI-driven robotic applications, these four requirements are critical:
1. Ability to accommodate real-world variability
In a real-world manufacturing environment, robots need to handle variation in parts, positioning and operating conditions. Physical AI promises to handle more of this variability with less effort. As advances in multimodal foundation models, world models, robot learning, simulation and other areas make robots increasingly capable, the execution layer grows in importance.
The handling is key here. If the EOAT cannot reliably handle variations in part sizes, shapes, and materials, then the model’s intelligence has limited practical value.
Grippers with adjustable gripping parameters and the flexibility to accommodate different parts and conditions give the system greater freedom to put that intelligence into practice.
2. More capable models require a reliable execution layer
Models can generate actions, but hardware must execute those actions. Models can infer that an object should be picked up, but a physical gripper must make contact, apply the right force, detect whether the object is secure, and respond if something changes. Every single time.
Robot motion is relatively mature compared with real-world manipulation. That’s because manipulation depends on physical variables that cannot be eliminated and cannot be modelled perfectly.
This makes basic execution feedback critical. Grip and part detection can confirm whether an object is present and whether a grasp has been successfully completed, giving the system a direct signal that the intended action actually occurred.
Grippers and tools shape what a robot can do and how it interacts with the physical world. Limited tools mean limited practical capabilities, whereas flexible, feedback-capable tools expand the range of options available to the system.
3. Contact-rich data is needed to complement simulation and vision
Simulation allows teams to train, test, and iterate quickly. Vision helps robots recognize objects, understand scenes, and plan actions. Both are important to physical AI, but neither fully captures what happens when a robot physically interacts with an object.
Reliable manipulation also requires physical feedback. How much force is needed to pick up the item? What are the contact dynamics – including friction, slip and deformation? This type of critical feedback is very difficult to reproduce in simulation only. A grasp that works in simulation may still fail in practice due to the uncertainty and variability of the real world.
Jan. 18-20, 2027 | Orlando, Florida
Your favorite three days of the year
Join executives and decision-makers to explore the forces shaping the year ahead, exchange insights, and build relationships that advance automation.
Related Posts
DEVELOP LLC Joins TLMI to Bring End-of-Line Automation Expertise to the Label Industry
DEVELOP LLC Joins TLMI to Bring End-of-Line Automation Expertise to the Label Industry FANUC Authorized…
The Emerging Direction of ISO/IEC TS 22440
This excerpt was originally published as part of a full article on the SRES website. Introduction…
Mainstay Digital Announces Mainstay One 3D Digital Asset Program for Automation OEMs
Plano, TX, September 29, 2026 Mainstay Digital, an industrial product visualization studio specializing in complex…
Leave a Reply